MIT teaches robots to get their bearings quickly in unfamiliar environments
MIT researchers have developed a new method that lets robots quickly map large, unpredictable spaces. The technology can be applied in search-and-rescue missions and other tasks that require autonomous navigation in difficult conditions. The algorithm analyzes sensor data and builds a three-dimensional model of the terrain in real time. It is optimized to run on board the robot, so it can operate autonomously, without a constant connection to an external server.
AI-processed from MIT News; edited by Hamidun News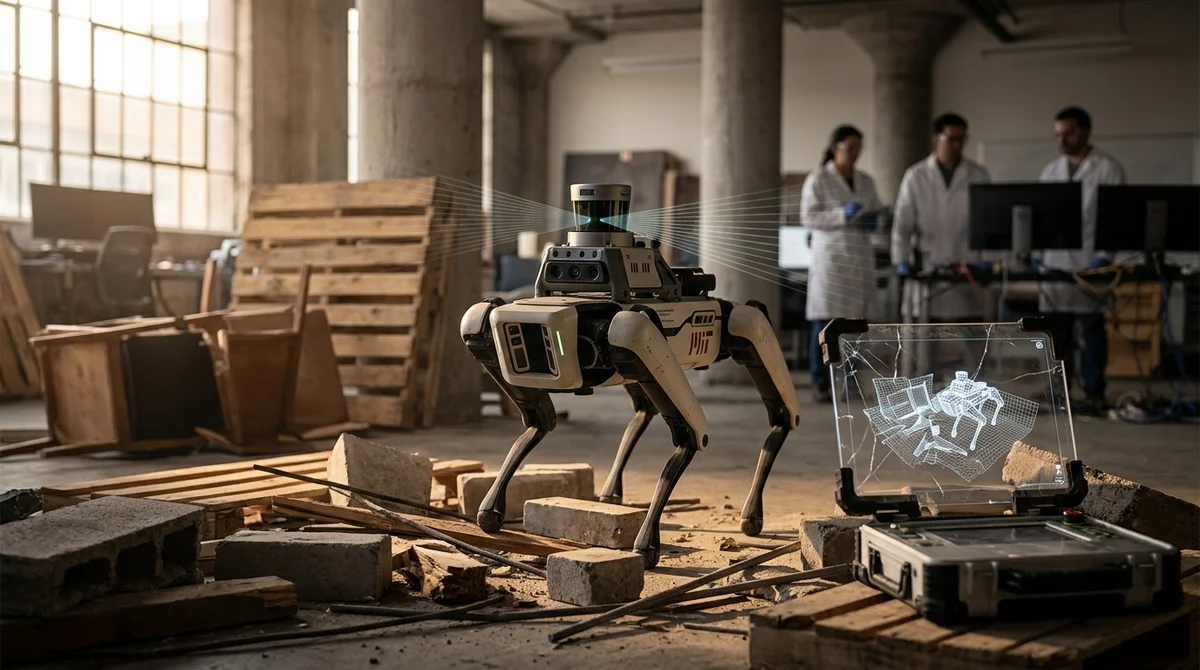
Imagine a robot that, like a seasoned explorer, instantly finds its bearings in an unfamiliar and dangerous environment. A team at the Massachusetts Institute of Technology (MIT) has taken an important step toward making that a reality, presenting an innovative approach to mapping large areas. The new development should let robots create maps of their surroundings quickly and accurately, which opens broad prospects for search-and-rescue operations, autonomous navigation and other critical fields.
At the core of the breakthrough is a complex algorithm that lets a robot analyze data from its sensors and build a three-dimensional model of the terrain in real time. The key difference from existing solutions is the speed and efficiency of this process. The robot can adapt quickly to changing conditions, avoiding obstacles and plotting an optimal route. This matters most in situations where every second counts, for example when searching for survivors in a disaster zone.
Traditional mapping methods often prove ineffective in dynamic and unpredictable conditions. They demand significant computing resources and time, which makes them unsuitable for real-time use. MIT's work addresses this problem with a more flexible and scalable approach. The algorithm is optimized to run on board the robot, so it can operate autonomously, without needing a constant connection to an external server.
The technology has enormous potential across industries. In search-and-rescue operations, robots equipped with the new mapping system will be able to quickly survey collapsed buildings and other hard-to-reach places, significantly improving the chances of saving people. In autonomous navigation, MIT's work will make it possible to build more reliable and safer systems for self-driving cars, drones and other robotic vehicles. The technology may also find uses in industry, construction and other areas that require accurate, rapid mapping of large territories.
The impact of the MIT work extends well beyond individual applications. It supports fundamental research in robotics and artificial intelligence. Scientists and engineers gain a powerful tool for studying and modeling complex spatial problems. That, in turn, spurs the creation of new, even more capable systems that can solve tasks that seem impossible today.
In conclusion, the new mapping approach developed at MIT is a significant step forward for robotics. It opens the door to more autonomous, efficient and reliable robots that can work in the most difficult and dangerous conditions. In the future, we will probably see this technology widely adopted in many fields, from search-and-rescue to autonomous transport and industrial automation. The key advantage is the ability to create maps quickly and accurately in real time, which makes the work especially valuable for tasks that demand a rapid response and adaptation to changing conditions.
- Nov 2, 2026DeepSeek Open-Sources Super-agent Prototype: p95 Task Time Drops from 29.5 to 15.7 Minutes
- Nov 2, 2026LLM Agent Built a Gearbox in KOMPAS-3D, but Scored Only 50 out of 100 on the Specification
- Nov 2, 2026Agents ignored the prompt to read memory in 7 of 7 sessions: an analysis of 13 thousand logs
- Nov 2, 2026Karpathy Built HackerTube, a Catalog of 6,454 Videos, in Two Hours with Claude Code
Test Frontier LLMs & Autonomous Agents in One Workspace
Run Claude Opus 5.5, GPT-6, Gemini 3.1, and DeepSeek side-by-side in Nomad AI (nomadnet.ai) — unified model routing, deep research, and multimodal workflows under one subscription.
The AI world, distilled — once a week
Seven stories that actually mattered, hand-picked. No noise, no reposts, no press releases.
Done! Check your inbox for a confirmation.