Tomato-picking robot learns to predict grasp difficulty and reaches 81% success rate
Researchers have built a tomato-picking robot that doesn't just spot ripe fruit: it predicts how difficult each grasp will be and picks the best approach angle. If an attempt fails, it changes its approach vector on its own. The success rate rose to 81%, against ~60% for standard systems. The authors see the future in cooperation: the robot takes on the monotonous work, and humans handle the non-standard situations.
AI-processed from Science Daily AI; edited by Hamidun News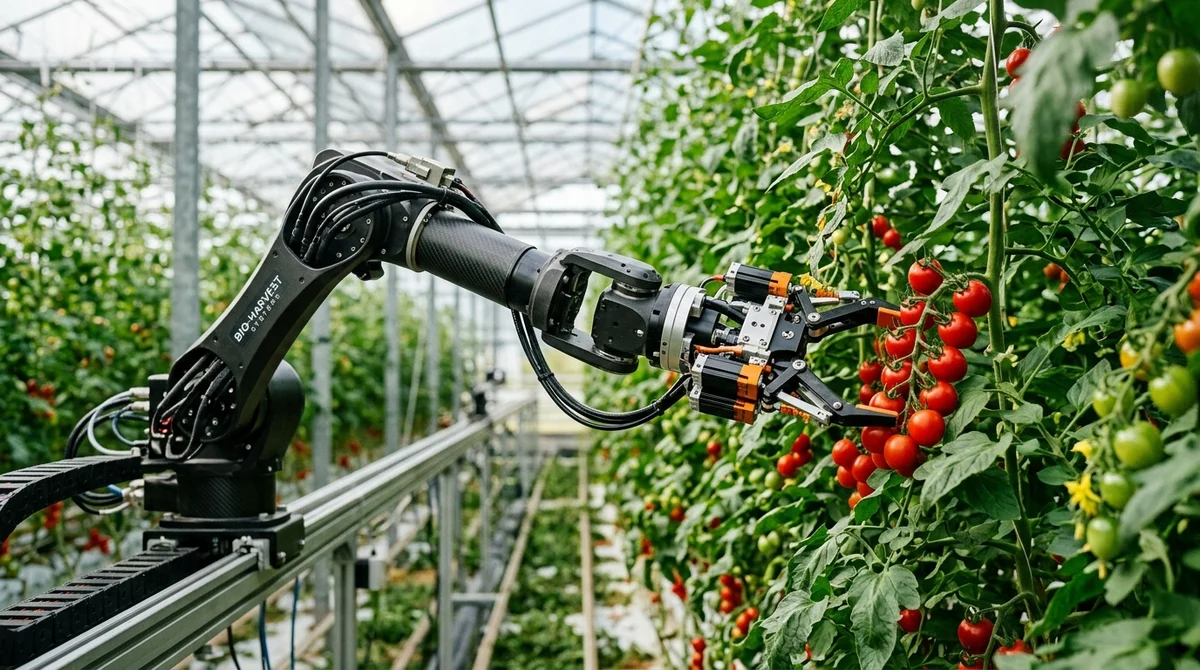
Researchers have developed a new tomato-picking robot that predicts how difficult an operation will be before each grasp and chooses the best strategy. The harvest success rate rose to 81%, roughly 20 percentage points higher than with classical systems.
Why conventional robots struggle
Agricultural robotics has long been able to recognize fruit ripeness. Neural networks learned to tell a red tomato from a green one with high accuracy. But recognition is only half of the task. The real difficulty lies in the physical action.
A real greenhouse is chaotic: dense trusses, hanging leaves, fruit at all sorts of angles, irregular shapes. A "found a ripe one → grabbed it" algorithm accounts for neither the approach angle, nor obstacles, nor the likelihood of damaging neighboring fruit. Every error means a lost crop or a damaged plant.
That is why the grasp success rate of classical harvesting robots rarely exceeds 60%. At industrial scale, that is unacceptable.
How the predictive approach works
The new system adds an intermediate step between "saw" and "grabbed." Before each movement, the robot builds a forecast: how accessible the fruit is, what stands in its way, and which force vector would cause the least damage. Based on this forecast, the system selects the best approach angle before the manipulator makes its first move.
If the first attempt fails, the robot switches to an alternative vector on its own, without halting the cycle and without operator involvement.
Crucially, the system was trained on real greenhouse data, not synthetic examples. Simulations do not reproduce the full complexity of living plants: wind, humidity, uneven ripening within a truss.
Test results
- 81% successful grasps, against ~60% for standard systems
- Real-time grasp-angle adaptation without restarting the cycle
- Works with clusters of fruit, not only single tomatoes
- Trained on real, not synthetic, data
The 20-percentage-point gap is significant: with thousands of fruits a day, that means hundreds of tomatoes saved per robot workstation.
Cooperation, not replacement
The authors stress that the goal is not to push people off farms but to create an effective environment for working together. The robot takes over the monotonous, precise work: choosing the angle, grasping, cutting. Humans handle what algorithms still do worse: non-standard situations, quality control, and adapting to sudden changes in conditions.
"The breakthrough opens the way to farms where robots and people work
side by side," the authors note.
This model reduces the physical load on greenhouse staff and lets robots be introduced gradually, without having to move the whole operation to automation at once.
What this means
The predictive logic of "assess first, then act" is a principle that reaches well beyond agriculture. The same architecture applies in warehouses, manufacturing, and medicine, wherever a robot has to work in an unstructured environment. Agriculture has historically lagged in robotization precisely because of this complexity.
If the 81% figure can be reproduced at industrial scale, the economics of farm automation will change significantly.
Key Questions Answered
Why conventional robots struggle?
Agricultural robotics has long been able to recognize fruit ripeness. Neural networks learned to tell a red tomato from a green one with high accuracy. But recognition is only half of the task. The real difficulty lies in the physical action. A real greenhouse is chaotic: dense trusses, hanging leaves, fruit at all sorts of angles, irregular shapes. A "found a ripe one → grabbed it" algorithm accounts for neither the approach angle, nor obstacles, nor the likelihood of damaging neighboring fruit. Every error means a lost crop or a damaged plant. That is why the grasp succes
How the predictive approach works?
The new system adds an intermediate step between "saw" and "grabbed." Before each movement, the robot builds a forecast: how accessible the fruit is, what stands in its way, and which force vector would cause the least damage. Based on this forecast, the system selects the best approach angle before the manipulator makes its first move. If the first attempt fails, the robot switches to an alternative vector on its own, without halting the cycle and without operator involvement. Crucially, the system was trained on real greenhouse data, not synthetic examples. Simulations do
What are the key details on Test results?
81% successful grasps, against ~60% for standard systems Real-time grasp-angle adaptation without restarting the cycle Works with clusters of fruit, not only single tomatoes Trained on real, not synthetic, data The 20-percentage-point gap is significant: with thousands of fruits a day, that means hundreds of tomatoes saved per robot workstation.
Test Frontier LLMs & Autonomous Agents in One Workspace
Run Claude Opus 5.5, GPT-6, Gemini 3.1, and DeepSeek side-by-side in Nomad AI (nomadnet.ai) — unified model routing, deep research, and multimodal workflows under one subscription.
The AI world, distilled — once a week
Seven stories that actually mattered, hand-picked. No noise, no reposts, no press releases.
Done! Check your inbox for a confirmation.