MTS shows how OpenClaw was wired to a robot, taking an AI agent into the physical world
MWS tested OpenClaw not only in the browser and in apps, but on real hardware. The team connected the agent to a Unitree G1 robot through a software layer that translates commands into remote-control signals, and sent the video stream to the multimodal model kimi-2.5. The result is a fast way to turn a "dumb" device into a physical AI executor without complex VLA development. The approach is not meant to replace full robotics stacks, but to assemble a working Physical AI prototype cheaply and quickly.
AI-processed from Habr AI; edited by Hamidun News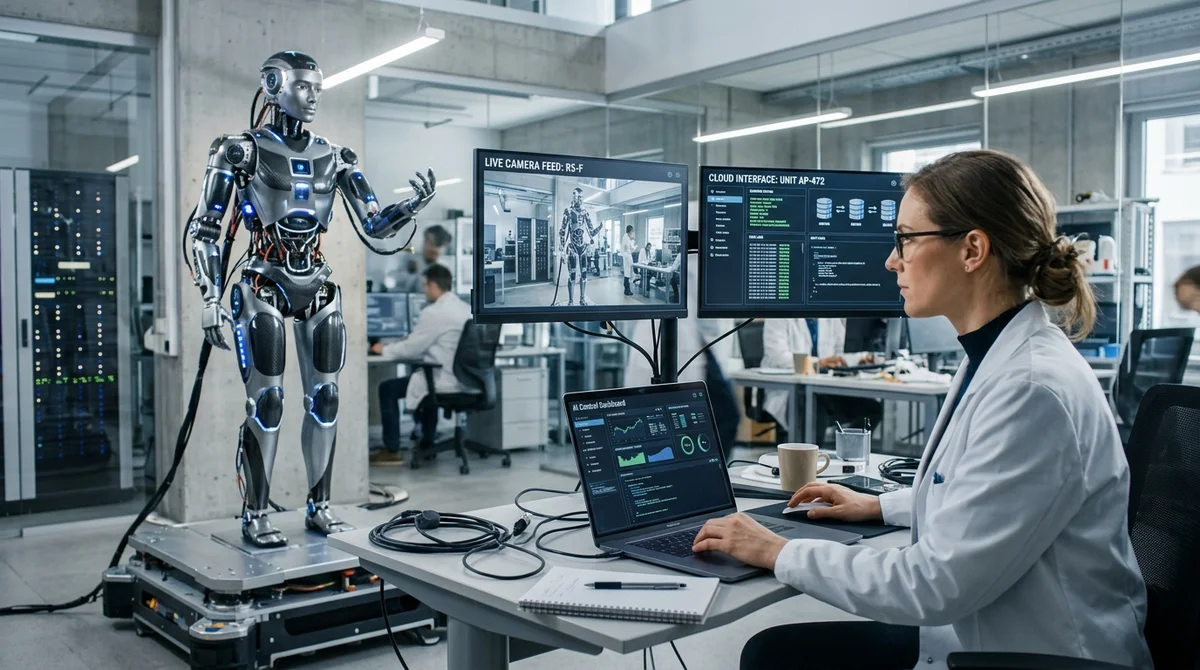
OpenClaw has shown that an autonomous agent can be taken out of the browser and into the physical world much faster than commonly assumed. The MWS team took an open-source orchestrator that usually controls a computer and its applications and linked it to a robot through a simple software layer. As a result, the agent no longer just performed digital tasks: it also issued commands to a real device, guided by a video stream and a multimodal model. The idea is not to replace proper robotics, but to build a working Physical AI prototype cheaply and quickly.
OpenClaw itself became a notable project in November 2025, when developer Peter Steinberger introduced an orchestration layer for autonomous computer use. The agent receives an instruction in a messenger, breaks it into steps, switches between applications, keeps context and, when needed, uses any compatible LLM. This independence from a specific model makes the system convenient for experiments: you can swap the reasoning engine without rewriting the top automation layer. For developers this is a rare combination: a low entry barrier, flexibility across models and ready-made logic for executing multi-step tasks.
This approach carries an obvious risk: if you install OpenClaw directly on a personal laptop, the agent effectively gets broad access to the entire system. MWS proposed a safer option: run it in an isolated virtual machine in the cloud. For this, a ready-made Ubuntu image with a preconfigured OpenClaw is used, and a configuration of 2 vCPU and 8 GB RAM is enough for the basic scenario.
After that, you issue a service account, create an API key and connect the LLM through the OpenAI-compatible GPT Model Hub endpoint. In other words, instead of assembling the environment by hand, the developer gets an almost one-click start. This matters not only for convenience: a separate environment is safer for testing scenarios in which the agent can open processes on its own, change the system state and store the context of working sessions.
The most interesting part began where articles about agent interfaces usually end: at the hardware level. MWS took a humanoid Unitree G1, which can walk, keep its balance and react to its surroundings, but is not a "smart" agent on its own. Instead of a complex VLA architecture, the team simply intercepted the remote-control logic: OpenClaw sends commands to an intermediate layer, which converts them into signals the robot understands.
The same scheme can connect not only an expensive humanoid robot but any device with an API or a radio remote, from a cart to a toy dog. The key point is that the intelligence layer is separated from the actuating mechanism, so the same agent can be moved between different types of devices.
So the agent would not act blind, the video stream from the robot's camera was fed into OpenClaw, and scene interpretation was handed to the multimodal model kimi-2.5. It recognizes objects, assesses the surroundings and helps choose the next action: move forward, stop, go around an obstacle or carry out a simple command in space.
Notably, the demonstration required neither MCP servers, nor heavyweight reasoning chains, nor a separate robotics platform. In essence, the team built a minimal bridge between an LLM agent, vision and an actuating device, showing that the entry barrier to Physical AI is now noticeably lower than many expected. That is the value of the case: it shows not an academic model of the future but an engineering recipe that can be repeated with available components right now.
The practical takeaway is simple: OpenClaw can already be used not only for emails, files and web interfaces, but also as a universal control layer for physical devices. This is not yet a replacement for full Vision-Language-Action systems, nor a path to reliable industrial autonomy, but it is a very fast way to test a scenario, build a demo or launch an applied prototype. For the market this is an important signal: the combination of a cloud LLM, a video stream and a simple control API is gradually turning Physical AI from a research curiosity into an engineering tool.
- Nov 2, 2026Microsoft releases 4B model Mage-VL-Cowork, which solves 66.0% of OSWorld-Verified tasks
- Nov 2, 2026Meta's Muse assistant keeps dossiers on loved ones and gets root on Ubuntu by default
- Nov 2, 2026mcp-linter finds 18 undescribed parameters in Anthropic's filesystem server
- Nov 2, 2026The Verge reviewer builds a $50 Meta Muse Charm alternative with Claude Code
Build & Ship Production AI Agents Without Boilerplate Code
Start your free 72-hour trial at Hamidun Academy (academy.hamidun.com) — interactive lessons on Claude Code & Cursor, live Tech Radar, and production agent templates.
The AI world, distilled — once a week
Seven stories that actually mattered, hand-picked. No noise, no reposts, no press releases.
Done! Check your inbox for a confirmation.